Breaking News
 A Quantum Physics Breakthrough Could Produce More Accurate Atomic Clocks...
Did Republicans Learn Their Lesson?
Balkanizing America at a Prodigious Rate of Speed
 See Watchtower in action
Top Tech News
 Researchers have discovered a massive deposit of hidden water...
 Amazon's Ring Unveils Flying Drone And Robot To Patrol Homes And Businesses
 Anthropic Strikes $3.4 Billion Off-Grid Power Agreement to Bypass U.S. Grids, Reports Say
 The X-ray room just shrank to the size of a laptop
 Dead Simple Apocalypse Power: Build It in an Hour
 Gritt and MasTec partner to bring physical AI to solar construction sites
 Baby it's cold INSIDE! Scientists create the coldest temperature ever recorded in the lab...
 I am IN LOVE with AIRCRETE! Off-Grid, Earth-Covered Dome
 Musk's Starlink Is Building An Orbital Bypass As Undersea Cable Sabotage Threats Mount
 A robot just built a structure in space for the first time
Bioinspired robot airdrops into remote waters via morphing wing-sail
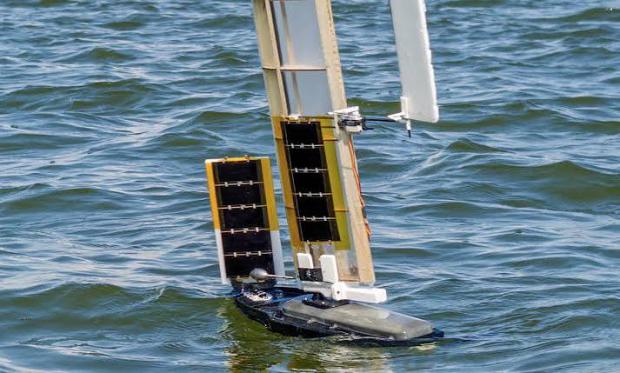
Researchers at the Singapore University of Technology and Design (SUTD) have developed what they call ALBATROSS, short for Airborne Lander with Buoyant AuToROtating Sailing Sensor; a nature-inspired, concept robotic platform that can be deployed from an aircraft over remote waters, land in water, straighten itself, and then sail autonomously using wind energy. The researchers say future deployments of the current prototype would be able to remain at sea for weeks at a time, monitoring environmental conditions.
Monitoring remote locations in the wide open sea presents a unique problem.
Boats and other watercraft can traverse a desired area for extended periods, gathering the required data. However, they may take a long time to travel from the deployment point to the desired destination. Aircraft, on the other hand, can reach a destination relatively quickly but cannot stay on station nearly as long as their sea-borne counterparts. The researchers' proposed solution combines the best of both worlds.
"Surface systems are useful because they can remain at sea, but they are constrained by how long it takes to get to the target location," says Prof. Foong Shaohui, Associate Head of the Engineering Product Development Pillar at SUTD. "With ALBATROSS, we wanted to use the best of both worlds: the speed of aerial deployment to reach remote waters quickly, and the endurance of sailing to remain there for long-duration monitoring."
In a practical scenario, an aircraft carries the ALBATROSS platform across open waters and deploys it over a designated area. The platform features two rigid wingsails that slow its fall through the air and also power it across the water, removing the need for a separate parachute or landing mechanism.
As it descends, the wings passively autorotate like a maple seed, slowing and stabilizing the platform as it approaches the water. Once it lands in the water, the platform rights itself and the wings act as sails, harnessing the wind to move around. The robot also features a fish-tail-inspired rudder for steering.
"We designed ALBATROSS to use the environment rather than fight it. It falls through the air using passive autorotation, rights itself on water through its weight distribution, and then uses wind to move," says Dr. Shane Kyi Hla Win, lead author of a paper published in Science Robotics. "That simplicity could enable lower-cost and more scalable platforms for sensing in places that are difficult to reach."
Once fully deployed in the water, ALBATROSS navigates autonomously between set waypoints using just three actuators and three navigation sensors. To test the concept, the researchers released a prototype from an altitude of 150 meters (492 ft). It stabilized during descent, landing on the water with low impact. It then autonomously righted itself and sailed off into the sunset. OK, not into the sunset, but around the test environment. The researchers estimate that a similar platform, without the autorotation system, would experience about 18.5 times more impact energy upon hitting the water.